The challenge
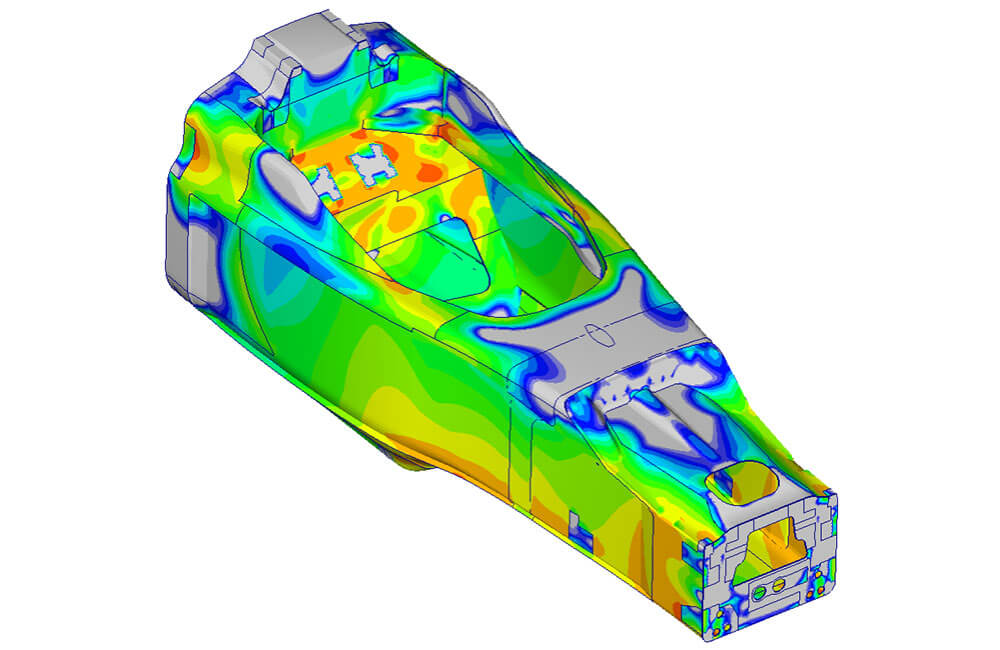
The project involved the structural analysis of the drill box, including both the composite outer enclosure and the internal mechanical components. The assembly was verified under the full range of mission load cases, including static loads associated with landing and drill operation, as well as dynamic launch loads represented by Power Spectral Density (PSD) acceleration spectra.
Our contribution
Throughout the project, we worked closely with both the mechanical design team and the composite manufacturing specialists to optimize the laminate lay-up and achieve the required structural performance while meeting mission requirements.
The drill box prototype was successfully validated through vibration testing on a shaker table. The experimental results showed excellent agreement with the finite element analysis (FEA) predictions, confirming the accuracy of the numerical model and the effectiveness of the design.
Gallery


Validate your product before you build it.
What if you could reduce your prototyping costs by up to 80%? Would you like to know how?
With computer simulation, we help you predict your product's performance under real operating conditions before it is manufactured. By identifying design issues early, you can minimize costly iterations, reduce development time, and launch reliable products right the first time.
Contact us todayFinite Element Structural Analysis FEA
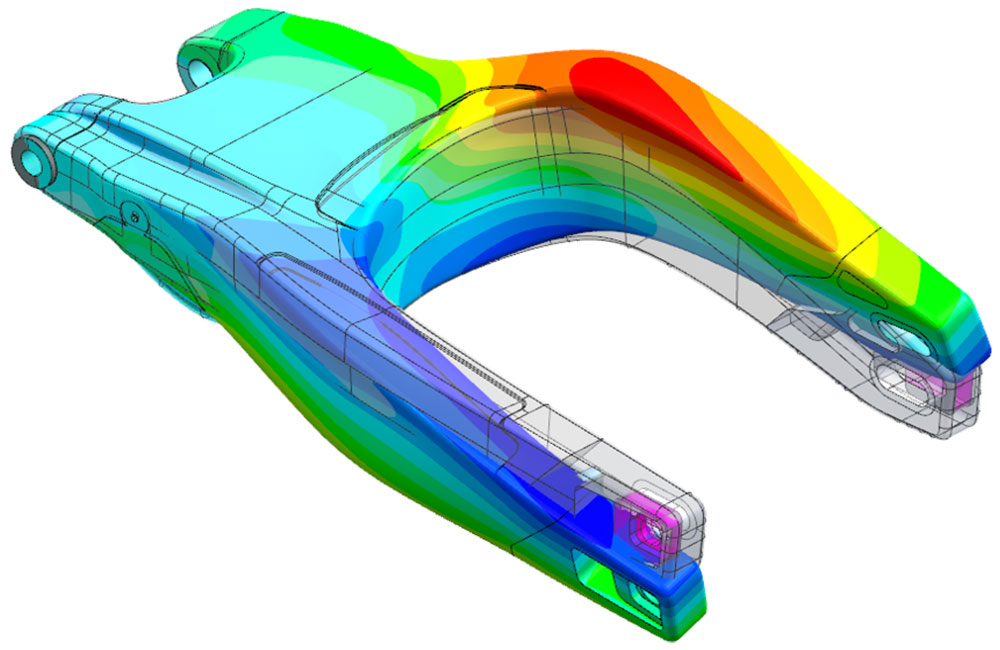
Using finite element analysis FEA, we help companies identify potential product performance issues and implement design improvements long before physical prototypes are built. Learn more about our finite element analysis services.
Dynamic Analysis & NVH
Dynamic and Noise, Vibration & Harshness analyses help predict product behavior and mechanical performance under vibration loading. Discover how we can help identify and solve vibration issues in your designs.
Composite Materials Engineering
More and more components originally designed in metal are being replaced with high-performance composite materials such as carbon fiber, delivering superior mechanical performance while reducing weight. Let us help you design optimized composite structures.
CAE Analysis Software
Looking to integrate Virtual Prototyping into your engineering workflow?
Discover our range of CAE software solutions and expert mentoring services. Our specialists will help you select the solution that best fits your needs and ensure its successful integration into your product development process. Contact us today for a free technical assessment.
View all softwareSimcenter 3D Dynamic Response
Simcenter 3D provides a complete solution for understanding, analysing, and improving system behaviour when subjected to dynamic loads.

Simcenter Femap Dynamic Response
Simcenter Femap provides advanced dynamic analysis capabilities, including frequency response, linear transient response, response spectrum analysis, random vibration, sine PSD, shock analysis, and more.